この商品を友人に教える:
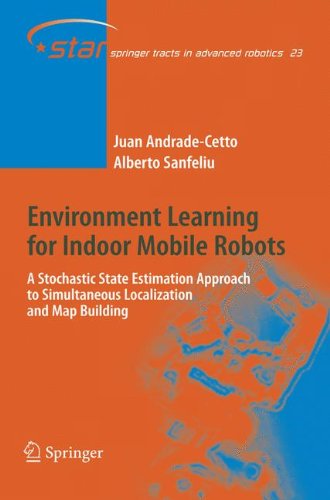
Environment Learning for Indoor Mobile Robots: A Stochastic State Estimation Approach to Simultaneous Localization and Map Building - Springer Tracts in Advanced Robotics Juan Andrade Cetto Softcover reprint of hardcover 1st ed. 2006 edition
価格
¥ 16.221
税抜
遠隔倉庫からの取り寄せ
発送予定日 年11月19日 - 年12月1日
 クリスマスプレゼントは1月31日まで返品可能です

Juan Andrade Cetto の新しいリリースのお知らせを受け取る

iMusicのウィッシュリストに追加
他の形態でも入手可能:
Environment Learning for Indoor Mobile Robots: A Stochastic State Estimation Approach to Simultaneous Localization and Map Building - Springer Tracts in Advanced Robotics
Juan Andrade Cetto
This monograph covers theoretical aspects of simultaneous localization and map building for mobile robots. One of the most relevant topics covered in this monograph is the theoretical formalism of partial observability in SLAM.
154 pages, biography
| メディア | 書籍 Paperback Book (ソフトカバーで背表紙を接着した本) |
| リリース済み | 2010年11月30日 |
| ISBN13 | 9783642069314 |
| 出版社 | Springer-Verlag Berlin and Heidelberg Gm |
| ページ数 | 136 |
| 寸法 | 155 × 235 × 8 mm · 226 g |
| 言語 | 英語 |





